POWERED BY WASPID INTELLIGENCE
WASPID MOMAR
A MACHINE BUILT FOR WORLDS BEYOND OURS.
An experimental autonomous rover platform designed for future multiplanetary exploration. Real hardware, real intelligence. Built by WASPID agents.
PROTOTYPE_V1.0
REAL HARDWARE
REAL VISION
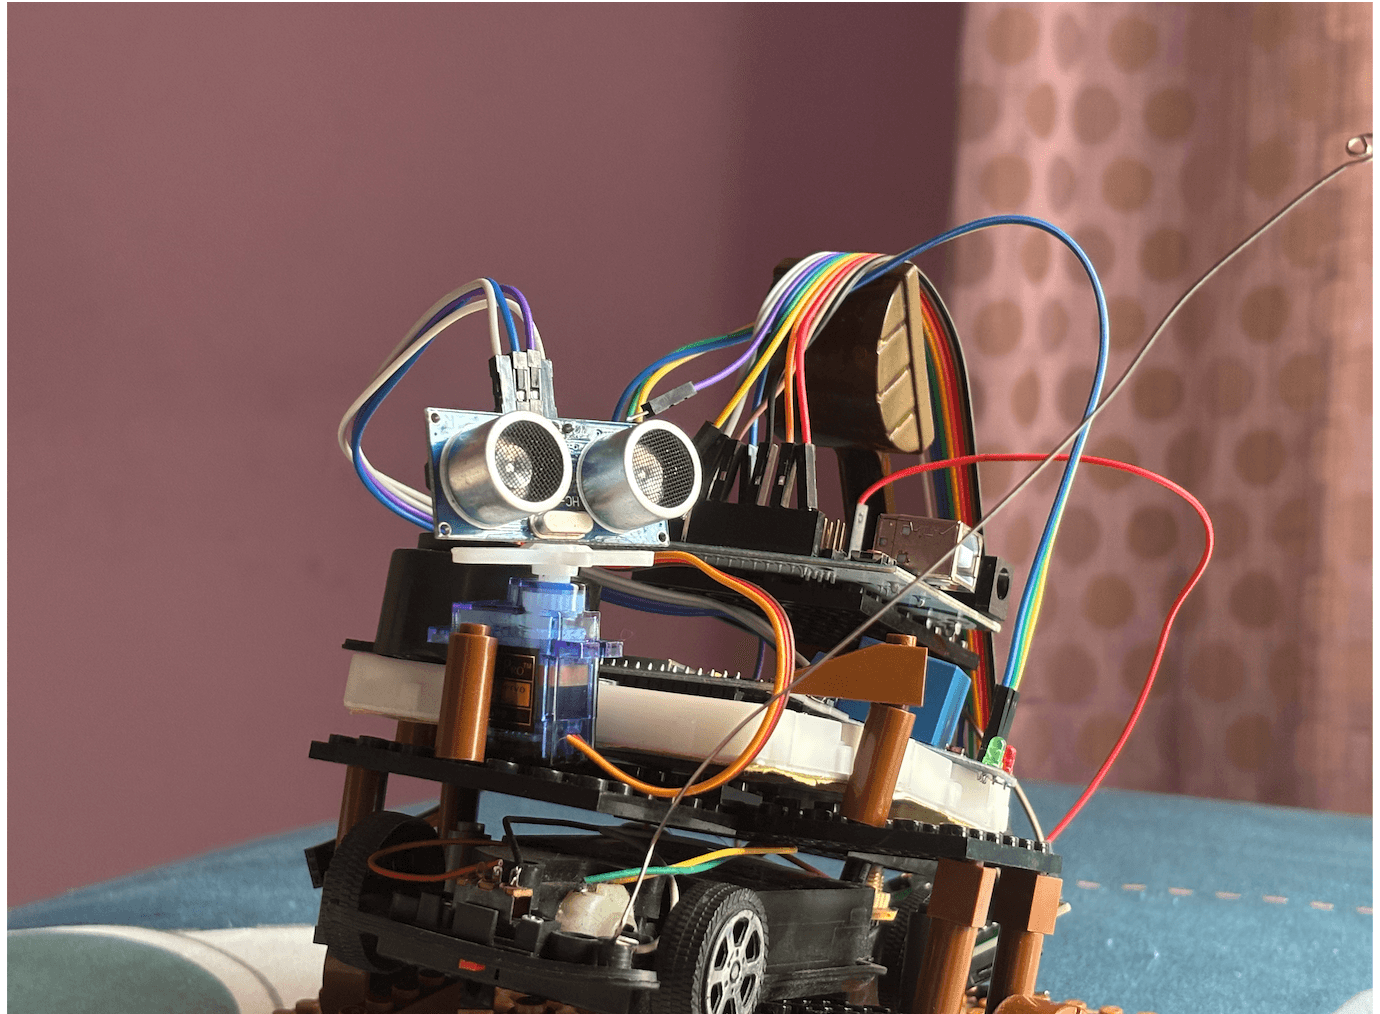
The first physical manifestation of autonomous exploration technology. Built from scratch with sensors, motors, and intelligence.
Ultrasonic Vision
Real-time obstacle detection and distance measurement
6-Wheel Drive
Six-wheel independent motor control for precise movement across uneven terrain
WASPID Intelligence
Autonomous decision-making and navigation algorithms
→ Built by WASPID Agents
FROM CONCEPT TO REALITYIN THE FUTURE
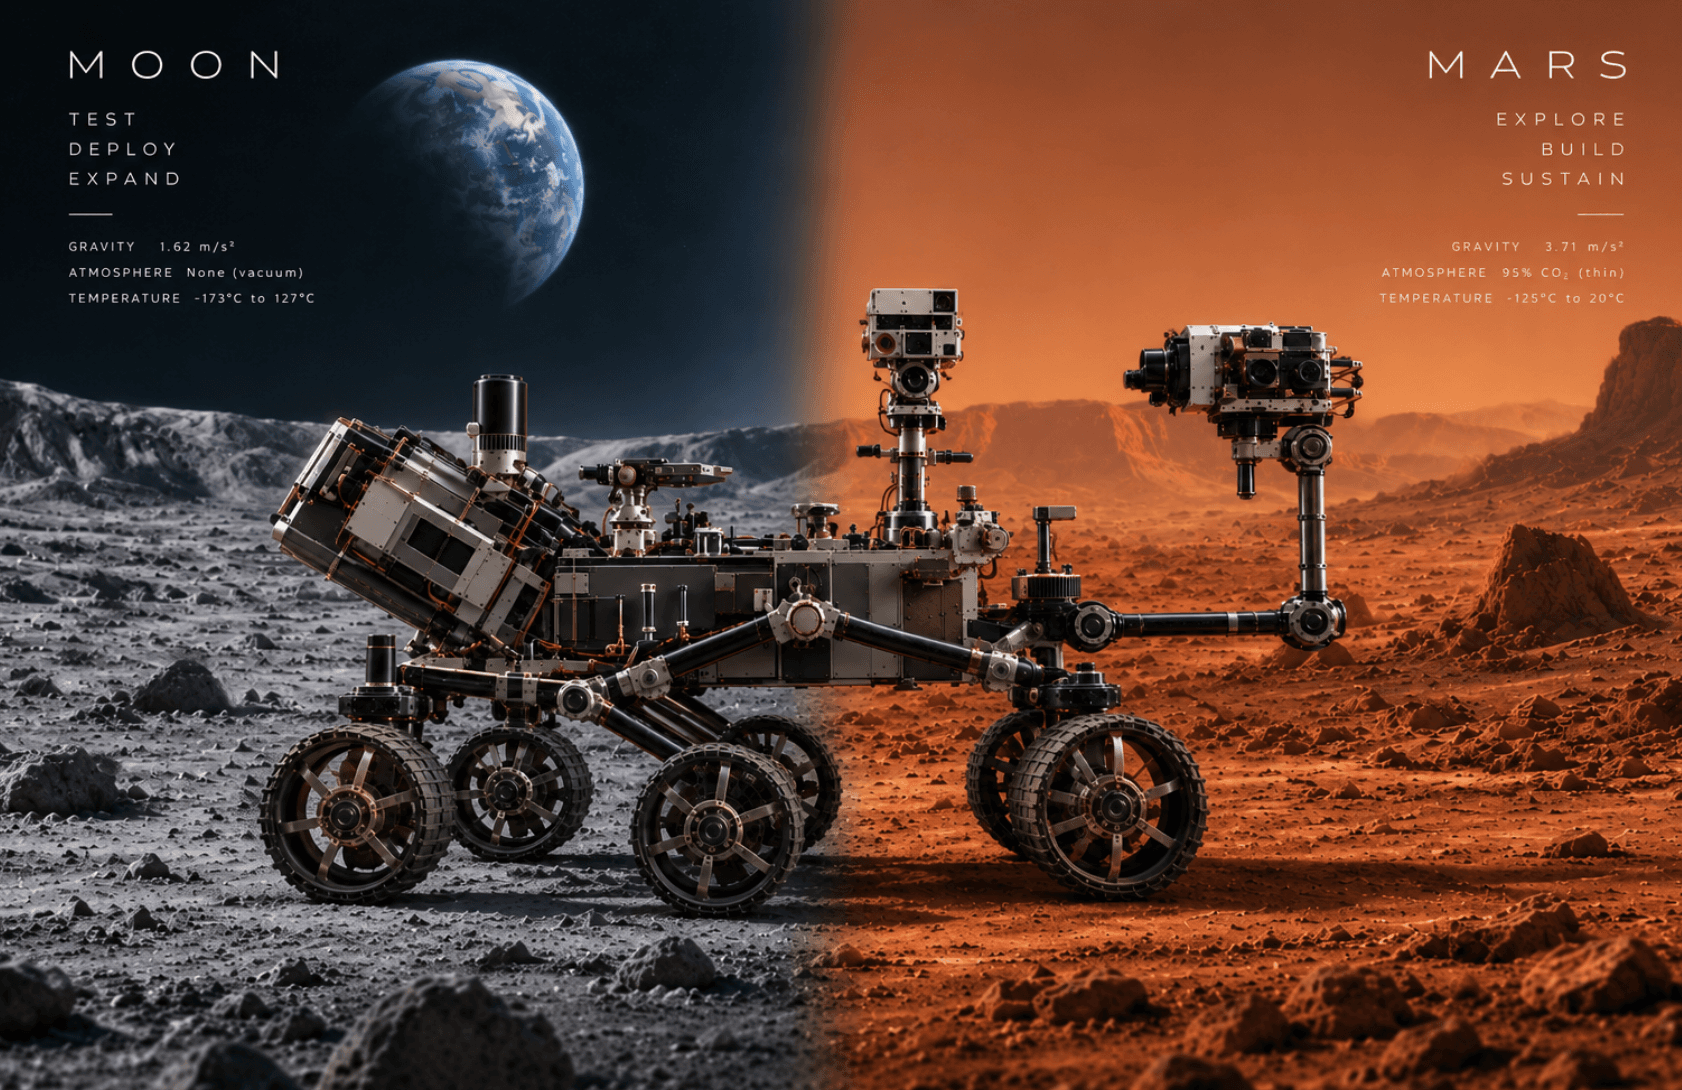
Our Moon and Mars rovers are still being built. This is where WASPID intelligence is headed next.
FIELD READY
Designed for extreme terrain. LED illumination for low-light operations. ESP32-powered navigation.
TECHNICAL VIEW
Top-down system architecture. Path planning visualization. Real-time sensor fusion from WASPID AI.
Built by WASPID • Powered by Autonomous Intelligence
SEE IT IN ACTION
Watch the WASPID MOMAR rover navigate autonomously. Real hardware, real intelligence, real movement.
Autonomous Navigation Test
WASPID MOMAR_ROVER_V1.0 • WASPID_CORE
STATUS: OPERATIONAL
MODE: AUTONOMOUS
Vision System
Ultrasonic sensors with real-time WASPID processing for obstacle detection and path planning
Mobility
6-wheel independent drive system with adaptive speed control, traction, and terrain response
Intelligence
WASPID autonomous decision engine running edge compute for real-time navigation
Powered by WASPID Intelligence
Autonomous robots built for exploration beyond Earth
ROCKER-BOGIE SUSPENSION
Watch the WASPID MOMAR rover navigate uneven terrain using advanced rocker-bogie suspension. Each wheel adapts independently to rocky surfaces.
Autonomous Navigation by WASPID Intelligence
SUSPENSION
Rocker-Bogie System
WHEELS
6x Independent Height
CONTROL
WASPID Autonomous
All-Terrain Capability
Rocker-bogie suspension allows each wheel to move independently, maintaining stability on uneven rocky terrain up to 45° slopes.
Adaptive Movement
Wheels adjust to different heights in real-time, powered by WASPID's terrain analysis and motor control algorithms.
Autonomous Path Planning
WASPID AI continuously calculates optimal paths, avoiding obstacles and selecting the safest route across challenging terrain.
Built by WASPID Agents
Robots & Rovers for Autonomous Exploration
→ Use buttons to switch camera angles • Drag to rotate • Scroll to zoom • Watch the rover navigate Mars-like terrain
WHAT MAKES
WASPID DIFFERENT
Not just another LLM platform. An AI operating system that knows when NOT to use an LLM.
The Intelligence Stack that Powers Autonomous Robots
WASPID CORTEX
Intelligence Orchestration
Automatically routes tasks to the best AI model. Coding → specialized model. Vision → vision model. Complex reasoning → reasoning model.
WASPID SWARM
Multi-Agent System
Multiple AI agents work together like a team. Planner, Builder, Critic, and Decision agents collaborate on complex tasks.
MEMORY DNA
Adaptive Long-Term Memory
Builds a knowledge graph for every project. Remembers what worked, what failed, and why. Never forgets important decisions.
WASPID PREDICT
Predictive Intelligence
Anticipates your next need before you ask. "You will likely need this next." Proactive, not reactive.
WASPID EVOLVE
Self-Improving System
Evaluates every action and learns from outcomes. Continuously improves strategies and workflows over time.
WASPID SHADOW
Error Detection & Verification
Every AI answer gets verified. Detects hallucinations, checks logic, validates API results. Ensures reliability.
THE WASPID INTELLIGENCE STACK
                    ↑ WASPID EVOLVE
                 Self-Improving System
                          │
                   ◆ WASPID CORTEX
                    AI Brain Router
                          │
            ┌─────────────┼─────────────┐
            │             │             │
        ⊕ SWARM      ▣ MEMORY       ⚡ PREDICT
       AI Agents      AI Memory      ML Engine
            │             │             │
            └─────────────┼─────────────┘
                          │
                   ◇ NEURAL ROUTER
                          │
         ┌────────────────┼───────────────┐
         │                │               │
        LLMs            ML Models        APIs
Every layer decides the optimal approach. Not every problem needs an LLM. WASPID chooses the right tool for each task.
WASPID is not an LLM platform
It's an AI Operating System
That decides when NOT to use an LLM. Faster. Cheaper. Smarter.
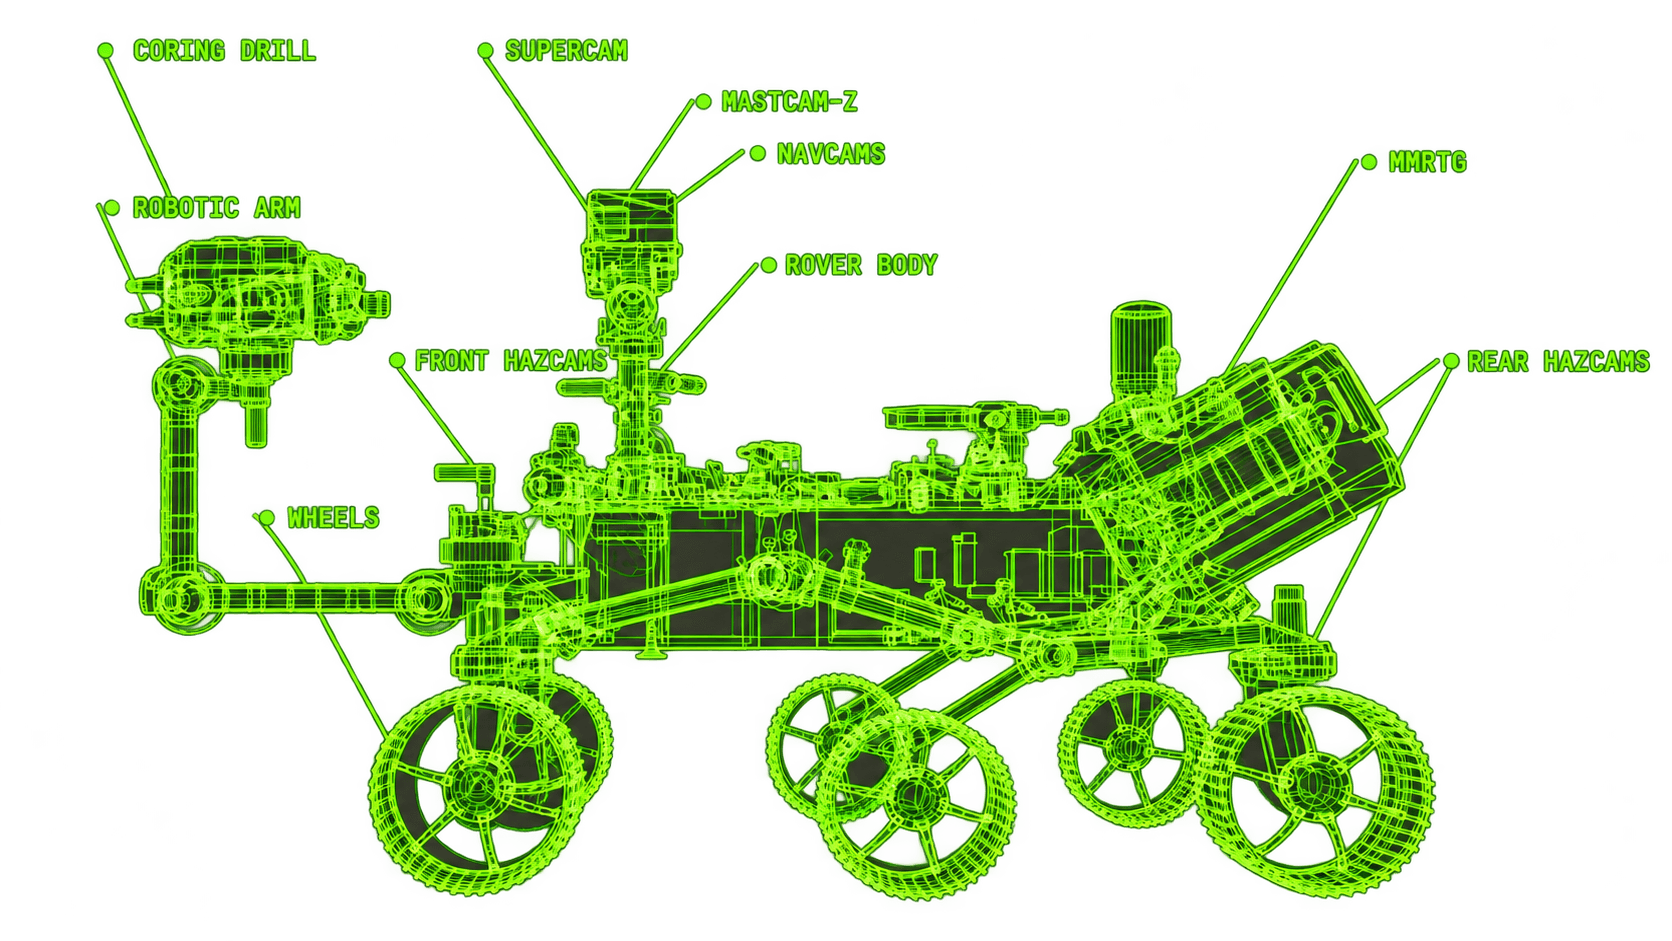
THE MACHINE
Interactive engineering blueprint. Hover to explore subsystems.
TAP TO EXPLORE
BUILT TO PERCEIVE
Four core capabilities. One unified autonomous system.
VISION
Multi-spectrum environmental perception and terrain mapping.
SENSE
Continuous environmental monitoring across all operational parameters.
THINK
Onboard decision engine for autonomous path planning and task execution.
MOVE
Six-wheel independent drive with adaptive suspension geometry.
FROM INTELLIGENCE
TO MACHINE
The evolution from artificial intelligence to autonomous hardware.
The Intelligence
WASPID
The Vision
IDEA
The Blueprint
SYSTEM ARCHITECTURE
The Brain
ROVER INTELLIGENCE
The Code
SOFTWARE
The Machine
WASPID MOMAR HARDWARE
THE INTELLIGENCE CAME FROM WASPID.
THE MACHINE IS WASPID MOMAR.
From software algorithms to physical robots — bridging artificial intelligence and real-world autonomy.
INTELLIGENCE THAT LEAVES THE SCREEN
PERCEIVE
REASON
DECIDE
MOVE
INTERACT
CODE TO TERRAIN
From software architecture to physical movement. The journey from digital logic to real-world action.
THE ROVER
Autonomous. Mobile. Real.
THE MISSION
From prototype to possibility.
Prototype & Validate
Ground-truth hardware testing. Validate mechanical systems, sensor integration, and core autonomy in controlled environments.
Perception & Navigation
Develop and integrate perception, navigation, and decision-making systems. Train the intelligence stack on real-world terrain data.
Difficult-Terrain Testing
Push hardware and software limits in harsh, unstructured environments. Desert, volcanic rock, ice — terrain that breaks assumptions.
Vision / Research
Long-term R&D vision — designing systems that could one day operate beyond Earth. This is a research direction, not a current capability.
BUILD STATUS
Real-time development status across all subsystems and components.
→ Development in progress. Status updates weekly.
THE LAB
Where hardware meets reality. A visual archive of our build process.
→ Images coming soon. Hardware is being built.